Xiao Liu (Leo)

Samsung Research America · Mountain View, California

I am currently a Senior Research Scientist in the Robot Intelligence Lab at Samsung Research America, where we are developing humanoid AI systems along with Foundation models. I earned my Ph.D. in Computer Science from the School of Computing and Augmented Intelligence at Arizona State University, supervised by Prof. Heni Ben Amor, and completed my Master's degree in Mechanical Engineering at Case Western Reserve University under the guidance of Prof. Kiju Lee.

My research focuses on Agentic Robotics, Robot Learning, and task planning, especially how to enable robots to understand task and scene in long-horizon scopes. My work has been presented at conferences such as CoRL, ICRA, and IROS.
Xiao Liu profile photo

News

Work Experience

Senior Researcher, Samsung Research America Manager: Kris Hauser

Full-stack humanoid robot AI infrastructure and agentic robotics for long-horizon tasks in home environments.

Postdoc Scientist, Honda Research Institute Manager: Soshi Iba

Context reasoning agents with large vision models and LLMs for long-horizon dexterous policies; scene graph‑based assistance for teleoperated avatar robots.

Research Engineer (part-time), RadiusAI Manager: Aykut Dengi

Multi-object tracking, monocular depth prediction, and multi-objective optimization for video analytics.
Publications

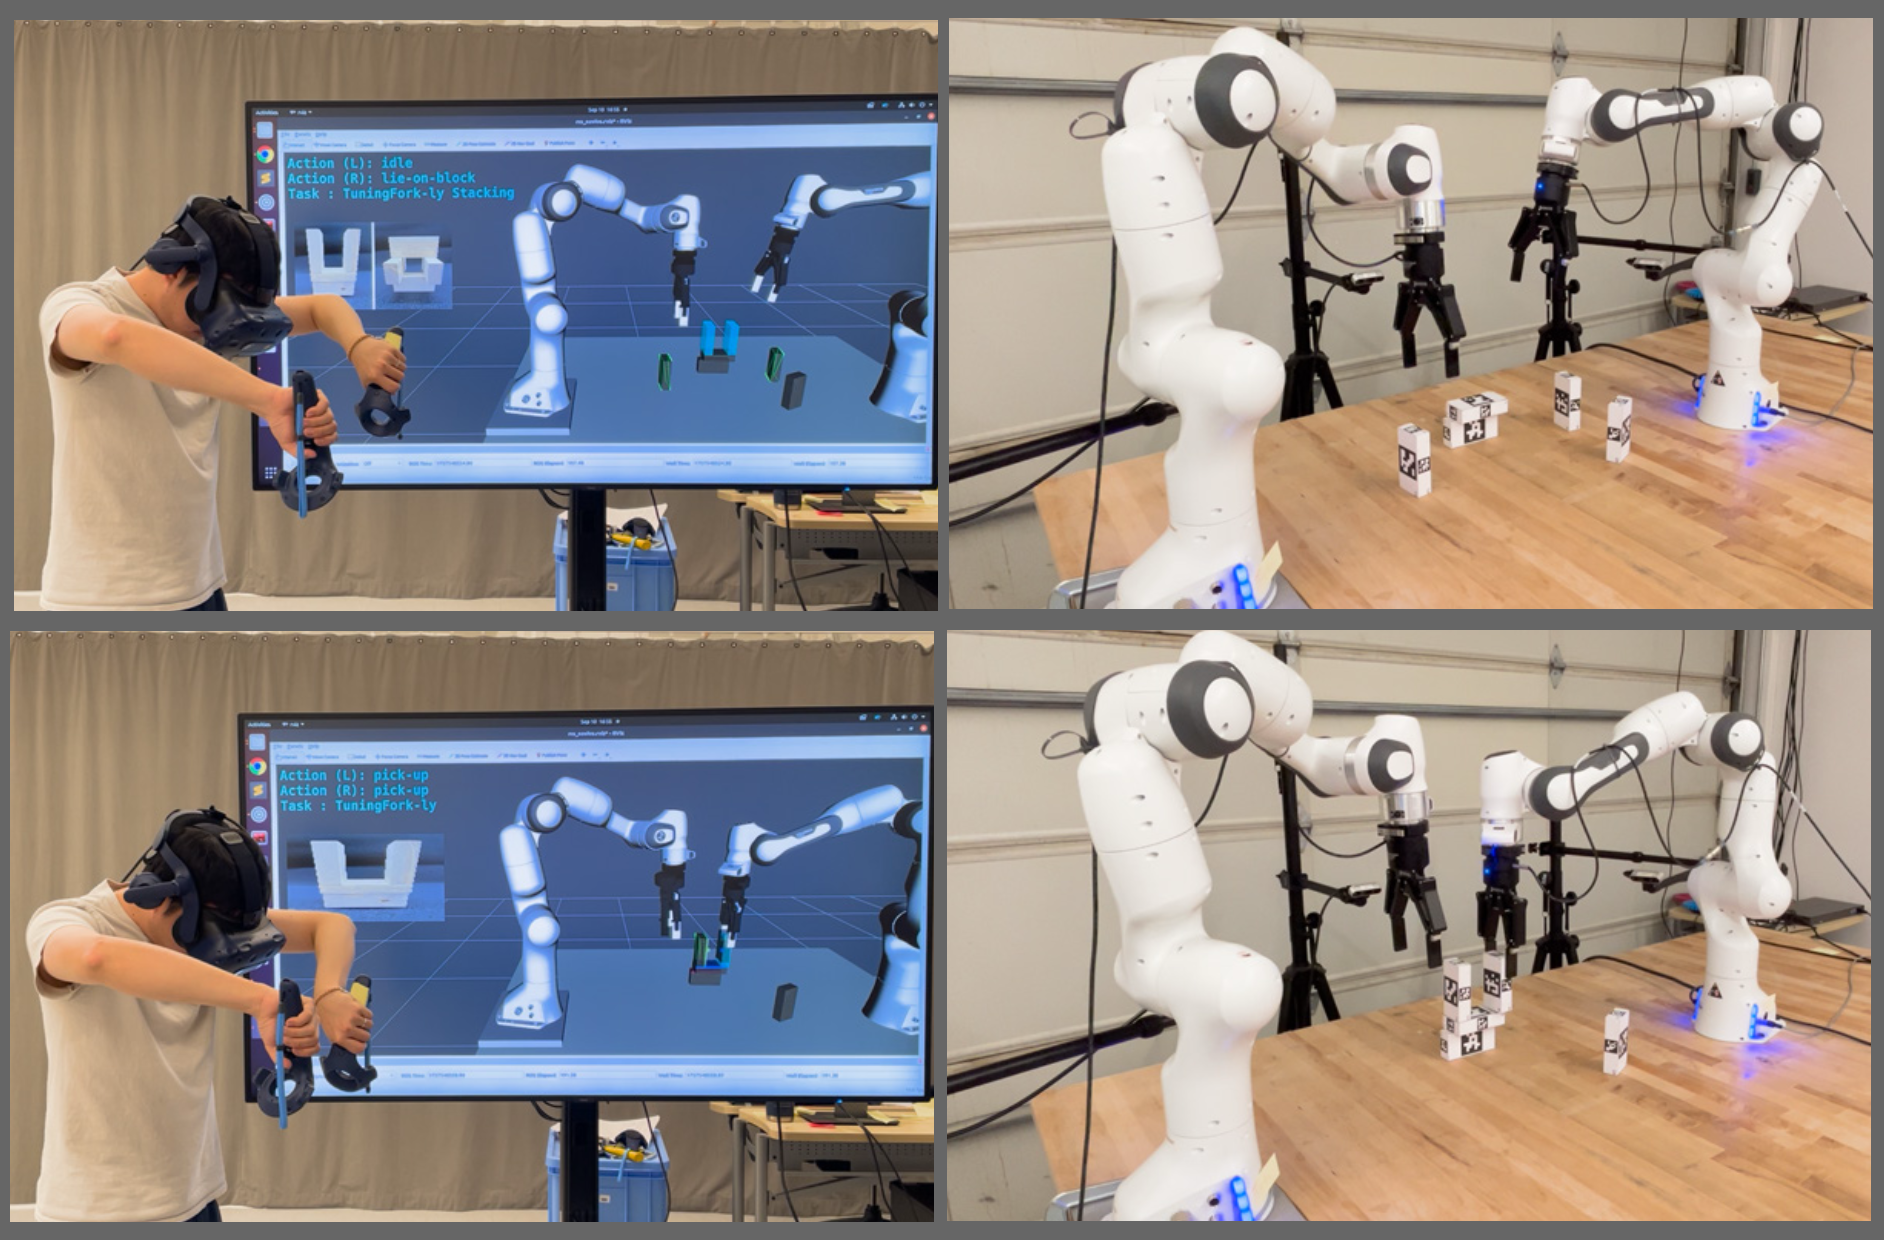
SUBTA: A Framework for Supported User-Guided Bimanual Teleoperation in Structured Assembly
Xiao Liu, Prakash Baskaran, Simon Manschitz, Wei Ma, Dirk Ruiken, Soshi Iba
IEEE International Conference on Robotics and Automation (ICRA), 2026 · Paper
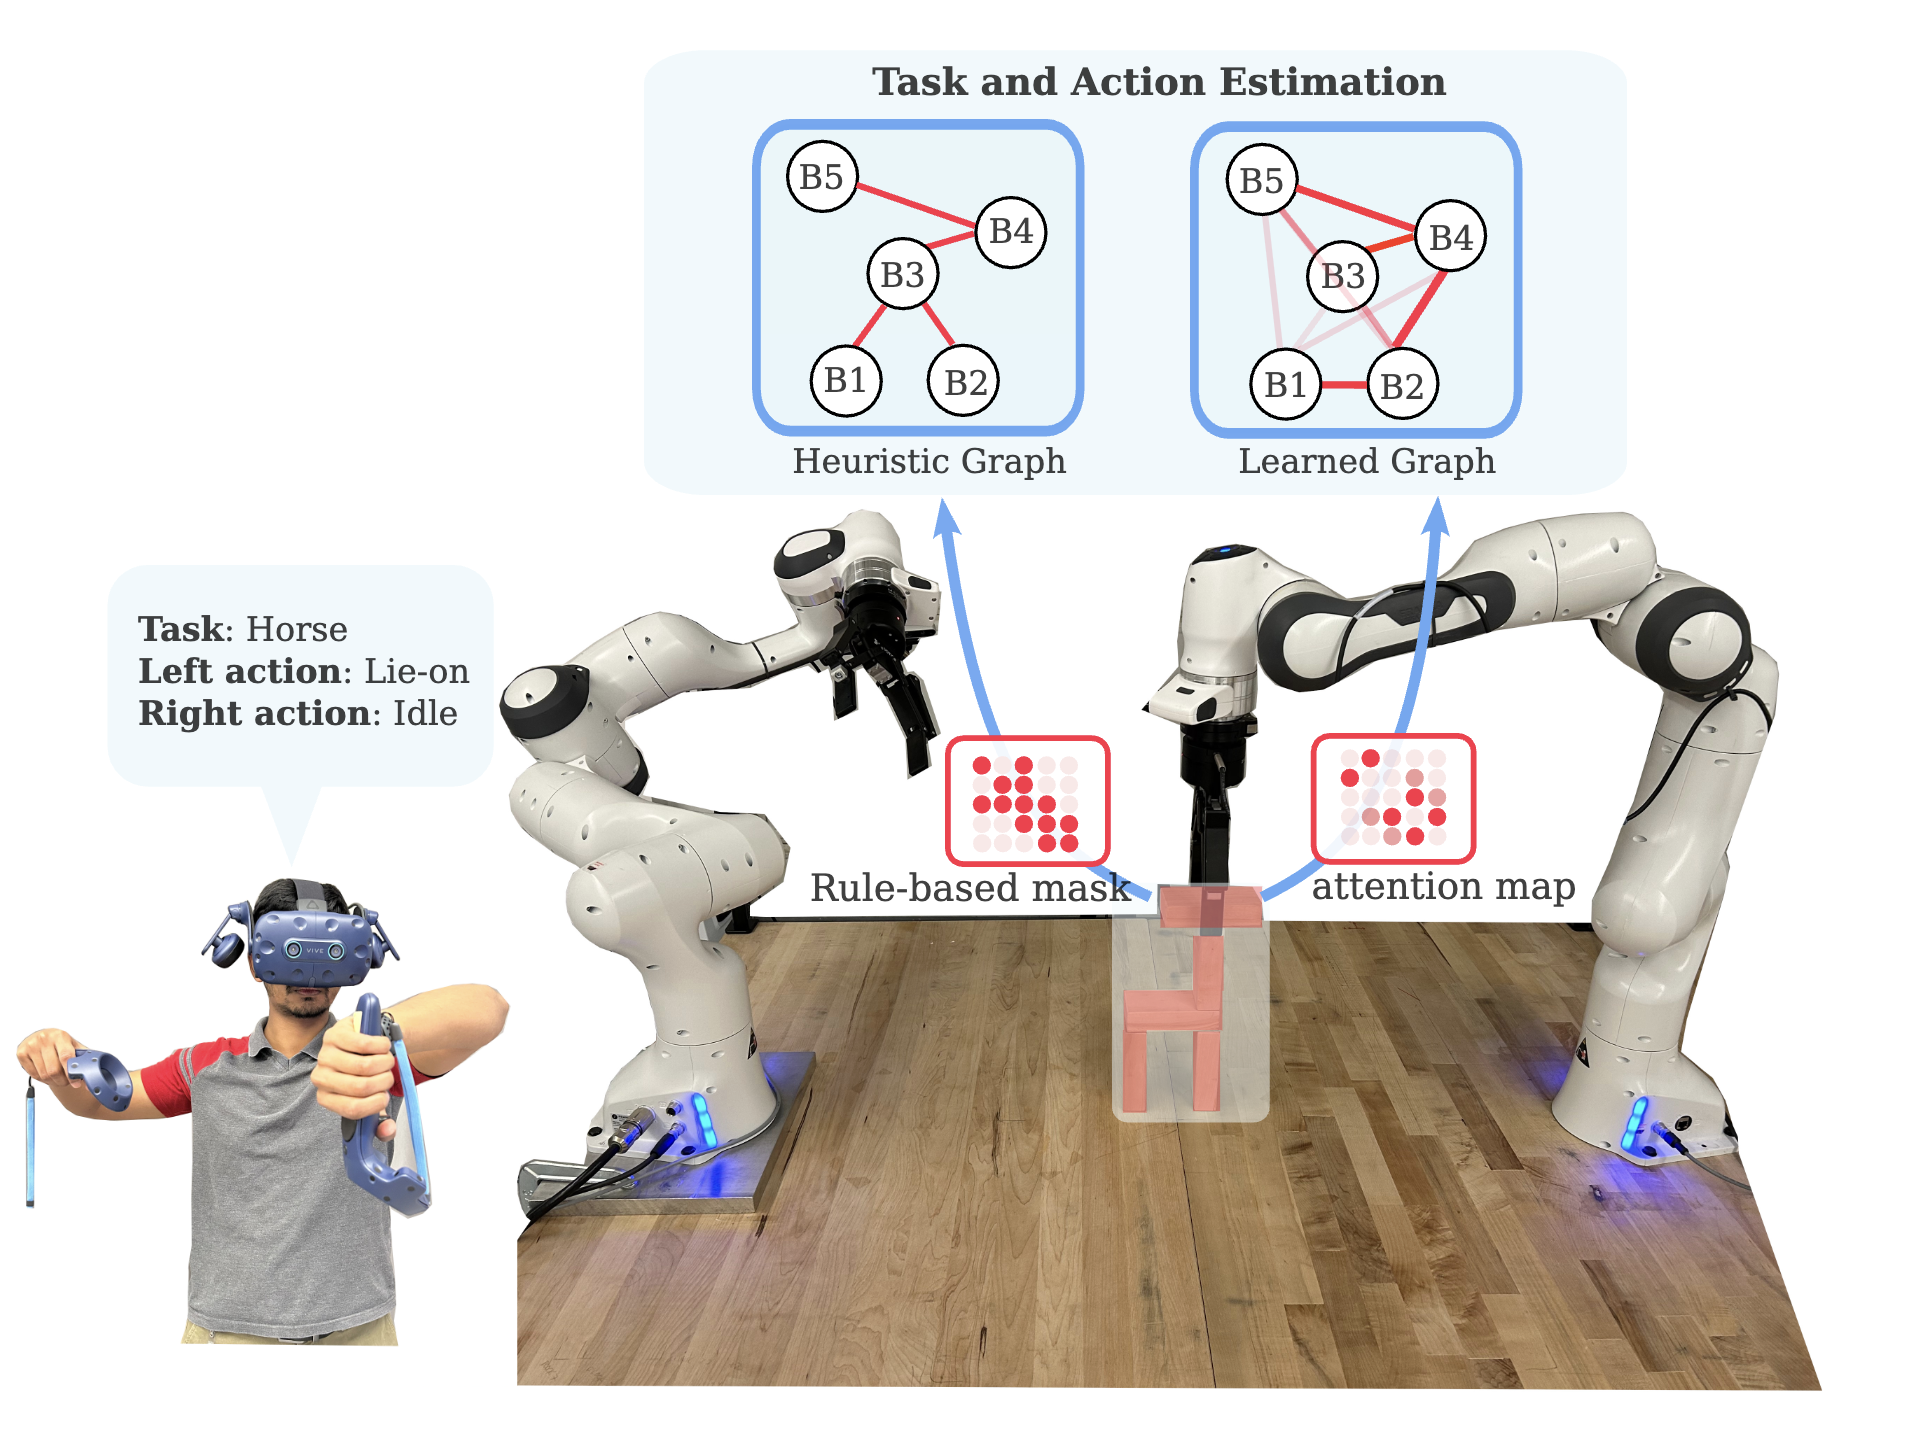
eXplainable Intention Estimation in Teleoperated Manipulation Using Deep Dynamic Graph Neural Networks
Prakash Baskaran, Xiao Liu, Songpo Li, Soshi Iba
IEEE International Conference on Intelligent Robots and Systems (IROS), 2025 · Paper
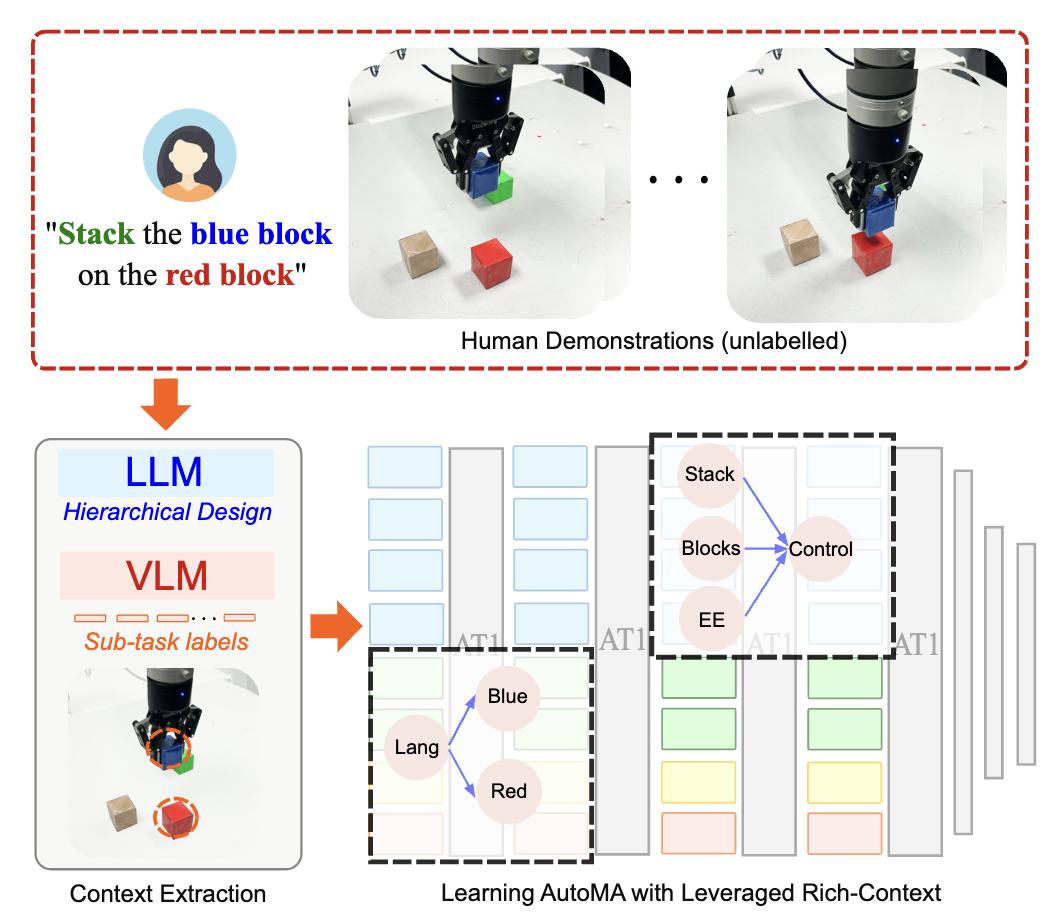
AutoMA: Automated Modular Attention enables Context-Rich Imitation Learning using Foundation Models
Yifan Zhou, Xiao Liu, Quan Vuong, Heni Ben Amor
IEEE International Conference on Robotics and Automation (ICRA), submitted, 2025 · Project Page · Paper
Robot Learning via Deep State-Space Model
Xiao Liu
Arizona State University, 2024 · Dissertation
Diff-Control: A Stateful Diffusion-based Policy for Imitation Learning
Xiao Liu, Yifan Zhou, Fabian Weigend, Shuhei Ikemoto, Heni Ben Amor
IEEE International Conference on Intelligent Robots and Systems (IROS), 2024 · Project Page · Paper
Enabling Stateful Behaviors for Diffusion-based Policy Learning
Xiao Liu, Fabian Weigend, Yifan Zhou, Heni Ben Amor
ICRA 2024 Workshop - Robot Learning Going Probabilistic, 2024 · Project Page · Paper
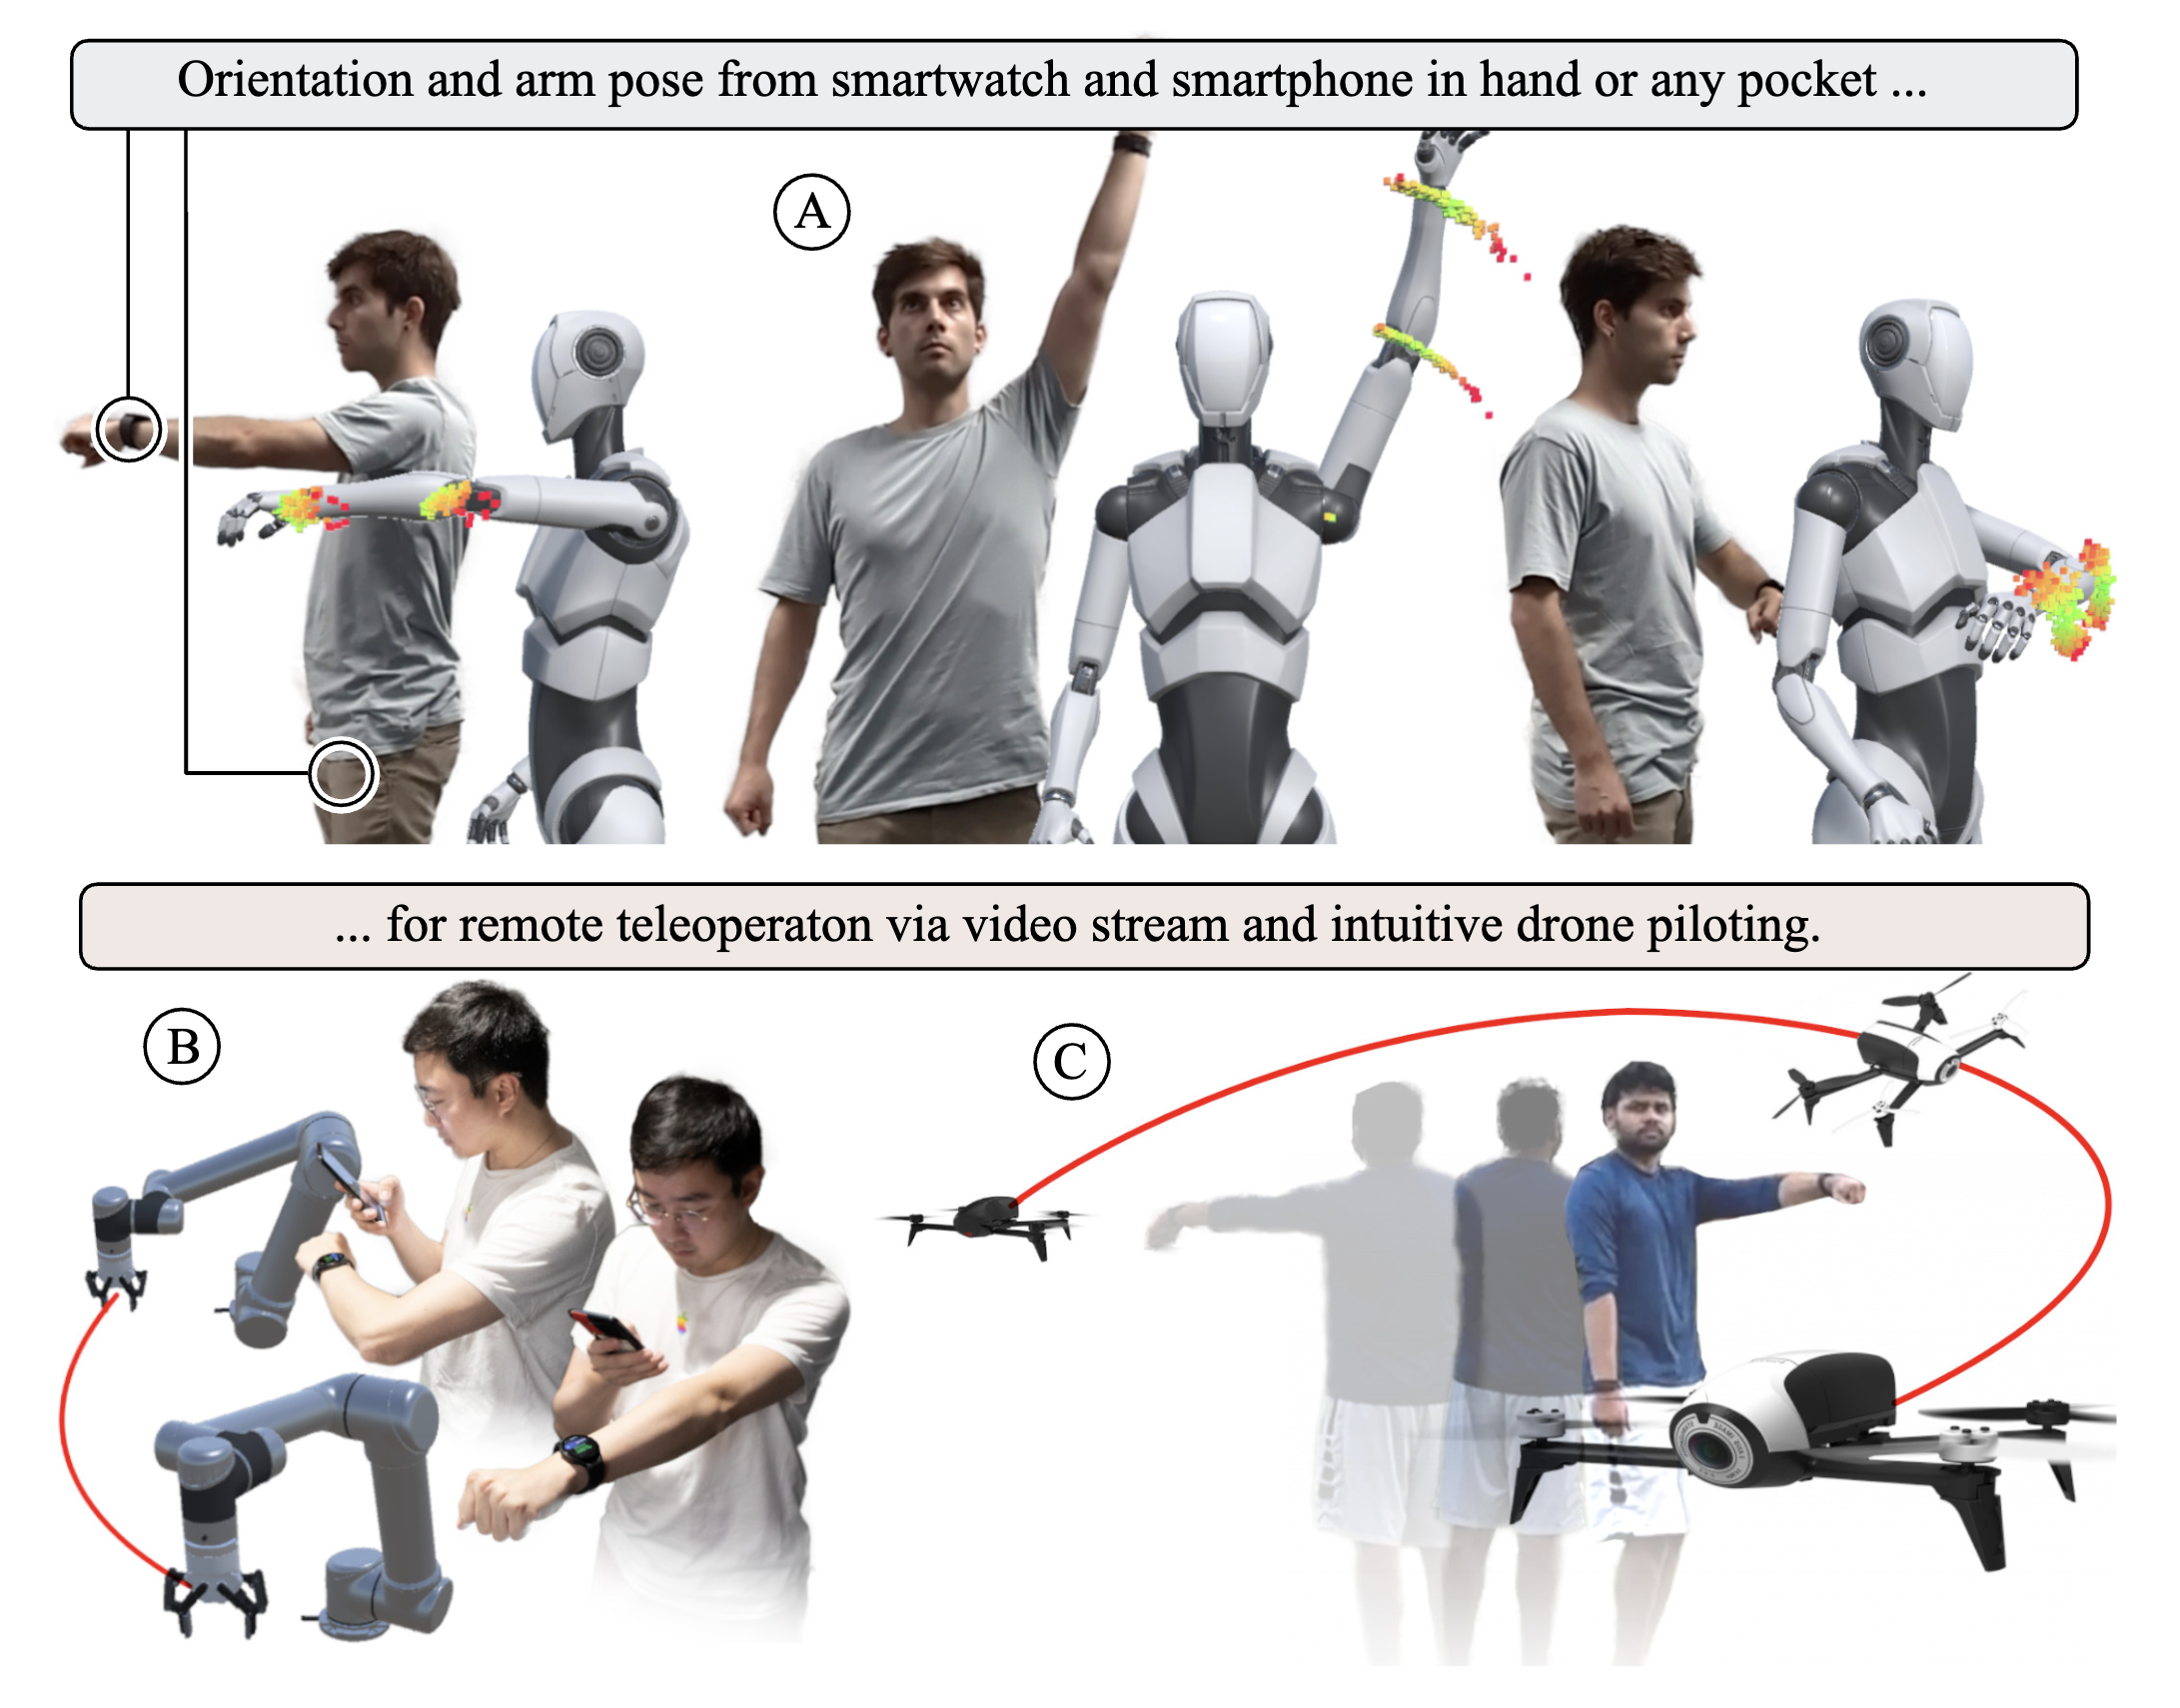
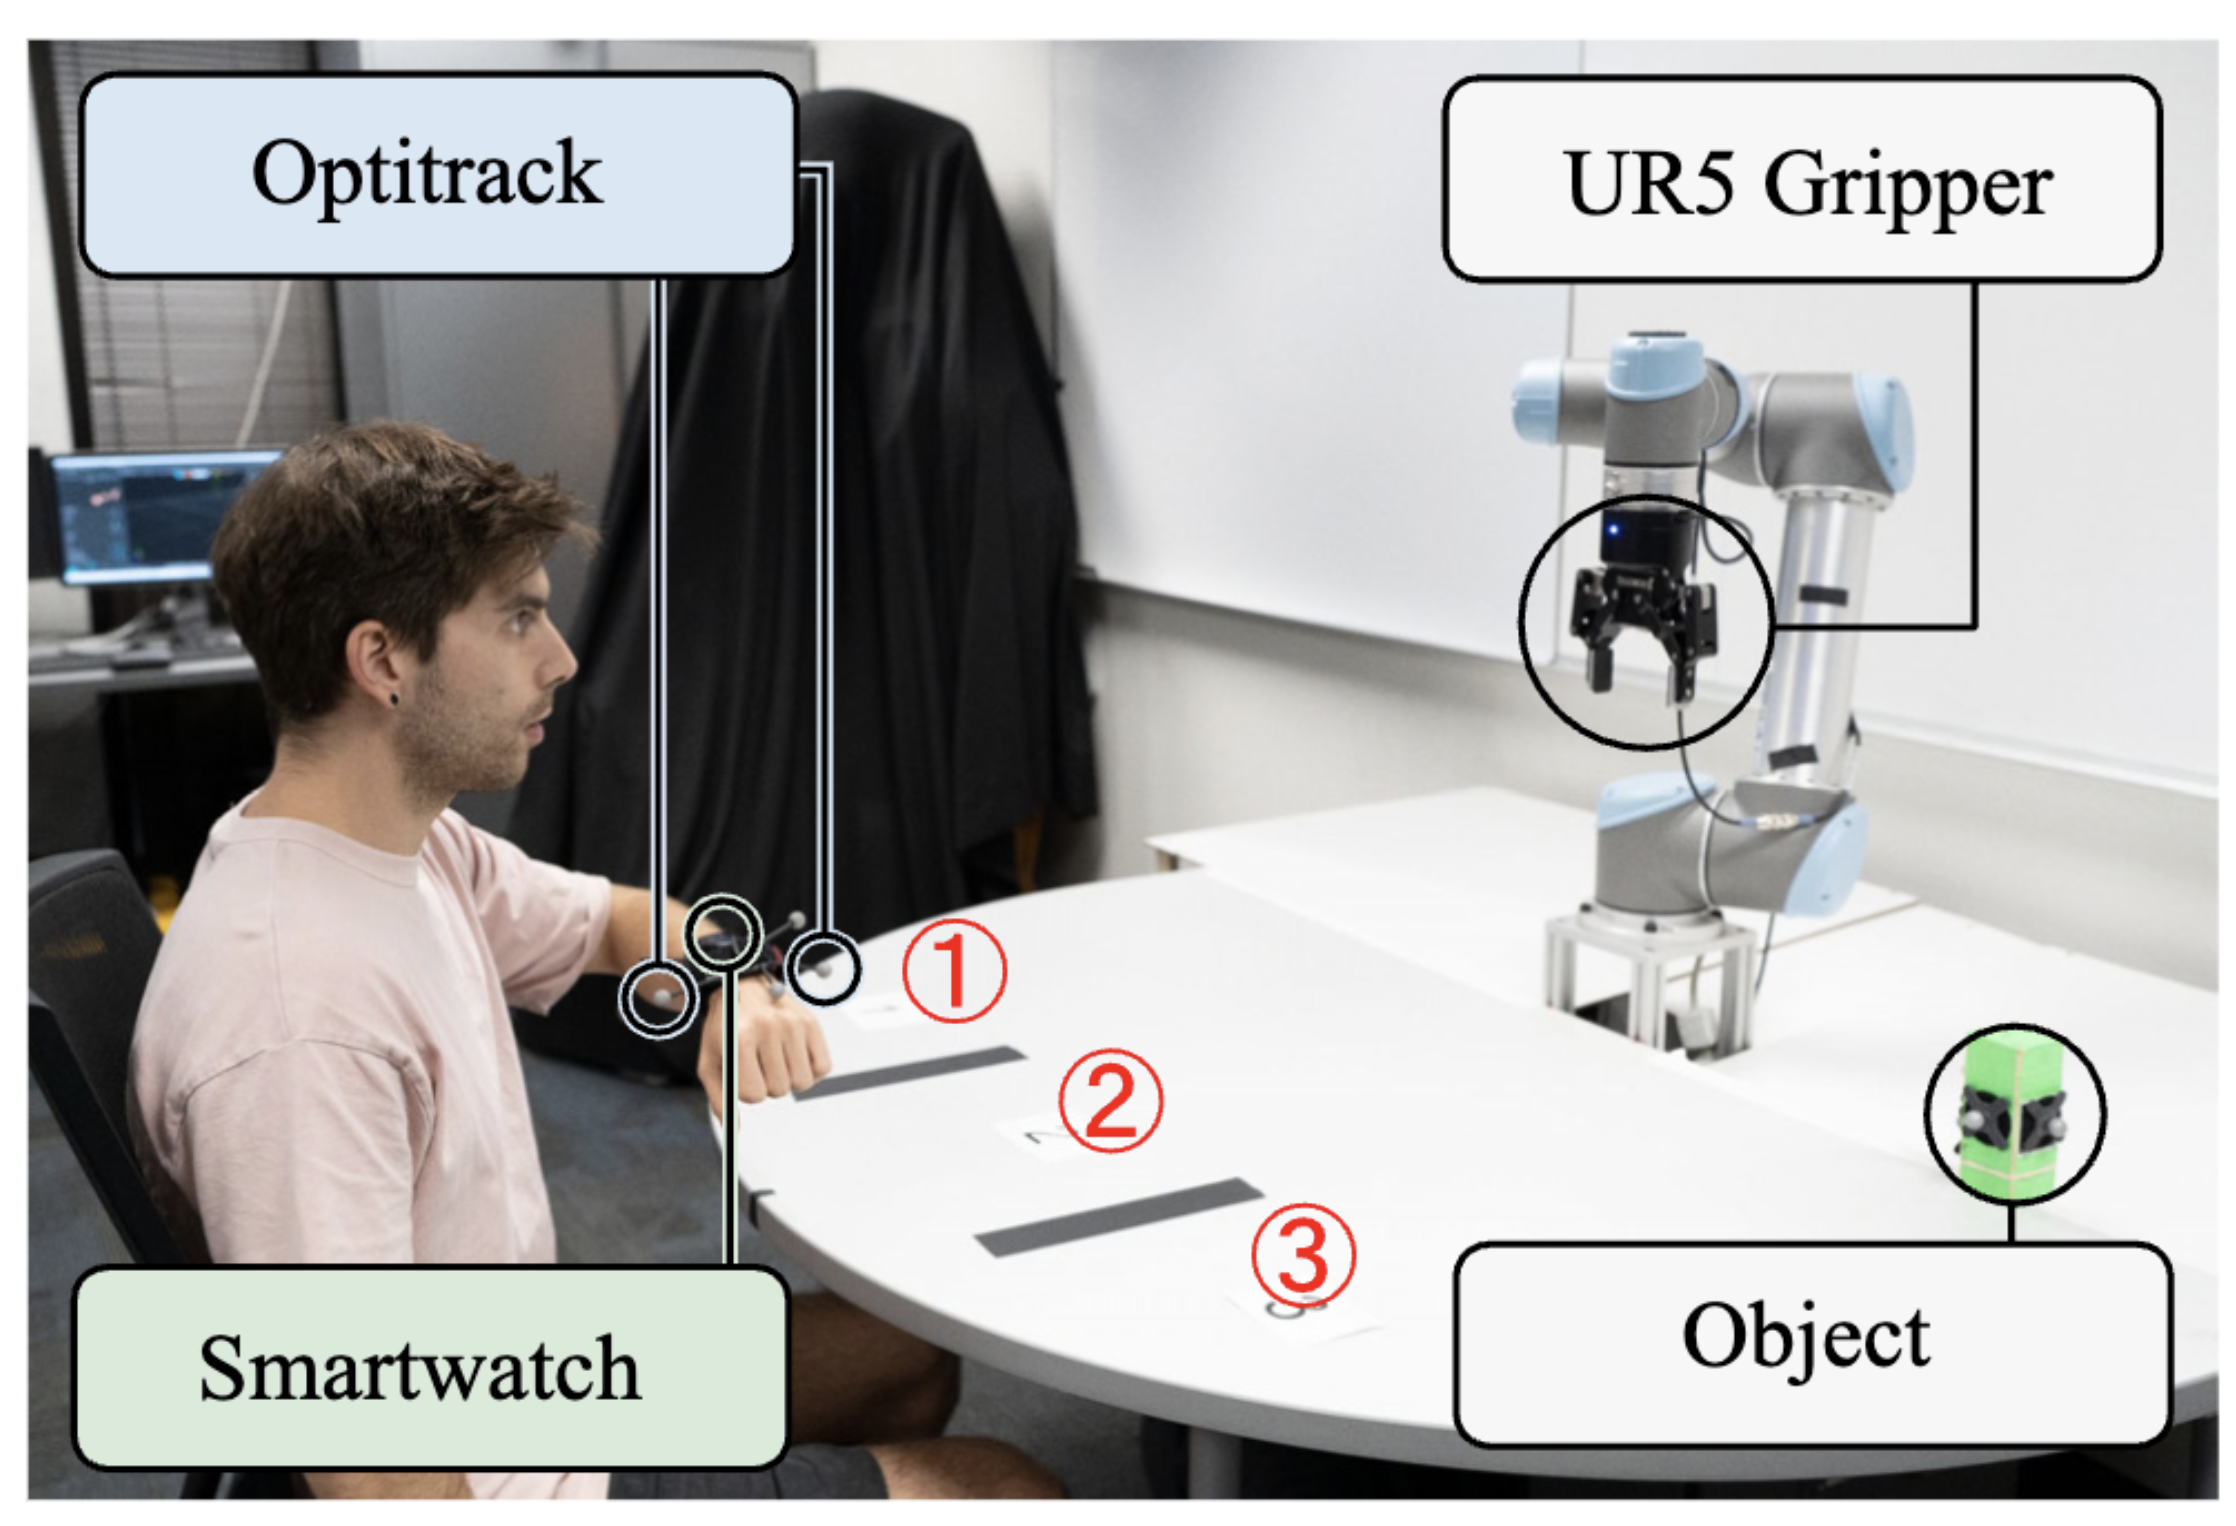
iRoCo: Intuitive Robot Control from Anywhere using a Smartwatch
Fabian Weigend, Xiao Liu, Shubham Sonawani, Heni Ben Amor
IEEE International Conference on Robotics and Automation (ICRA), 2024 · Project Page · Paper · Video
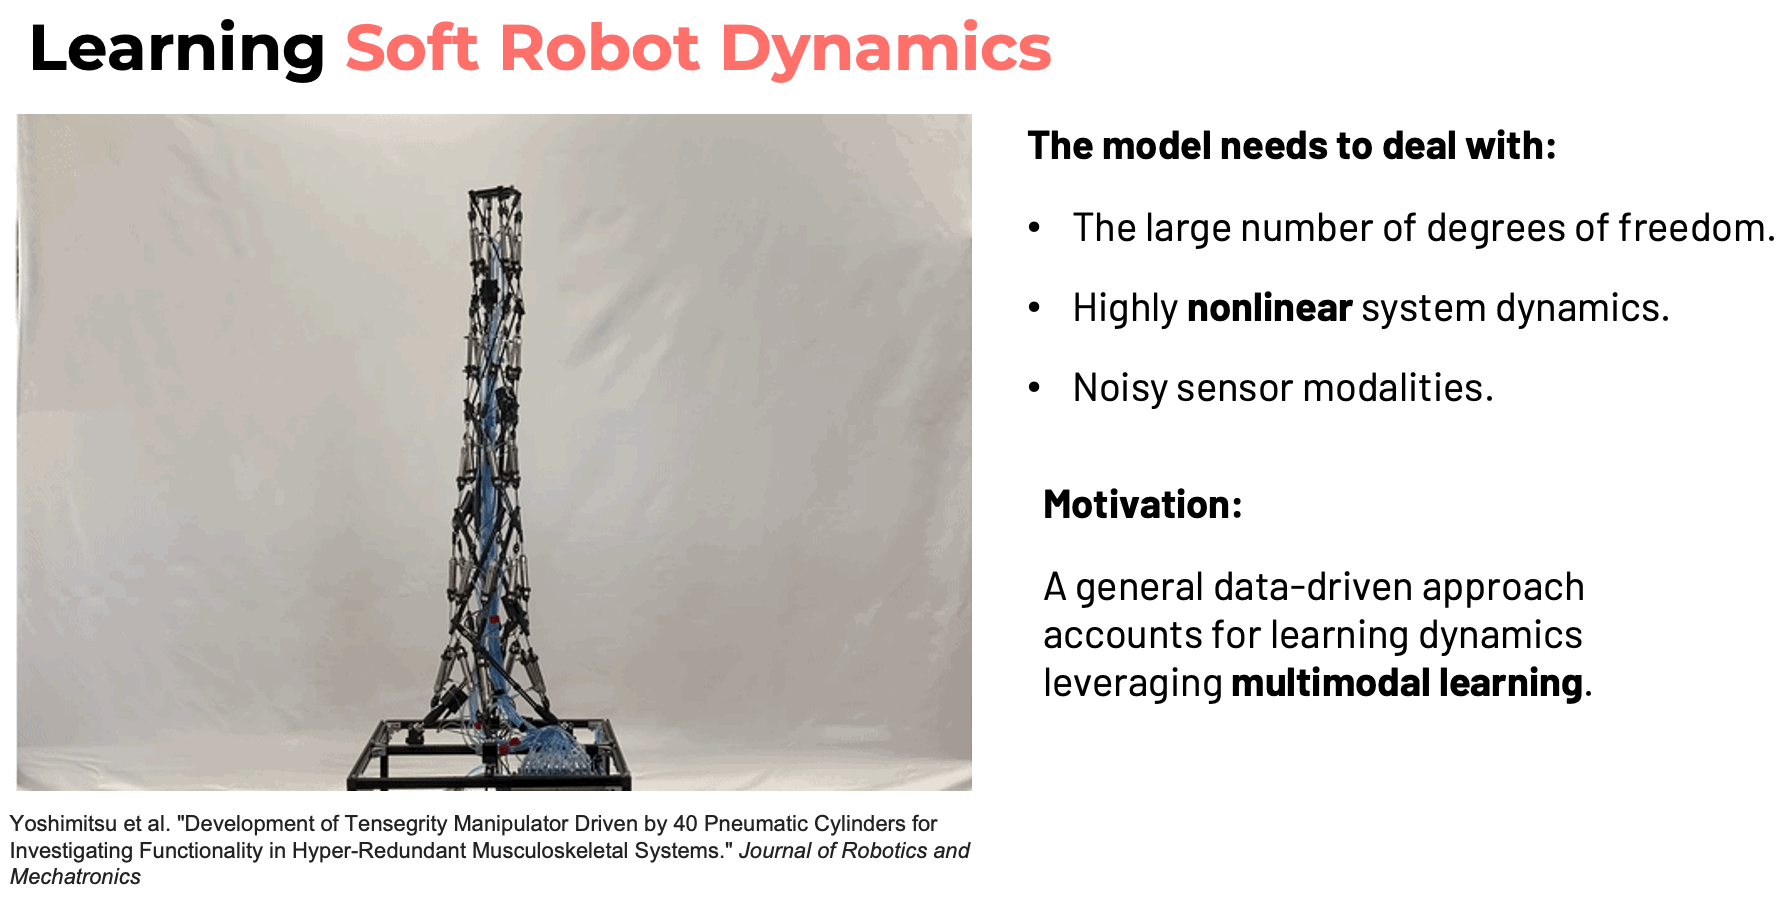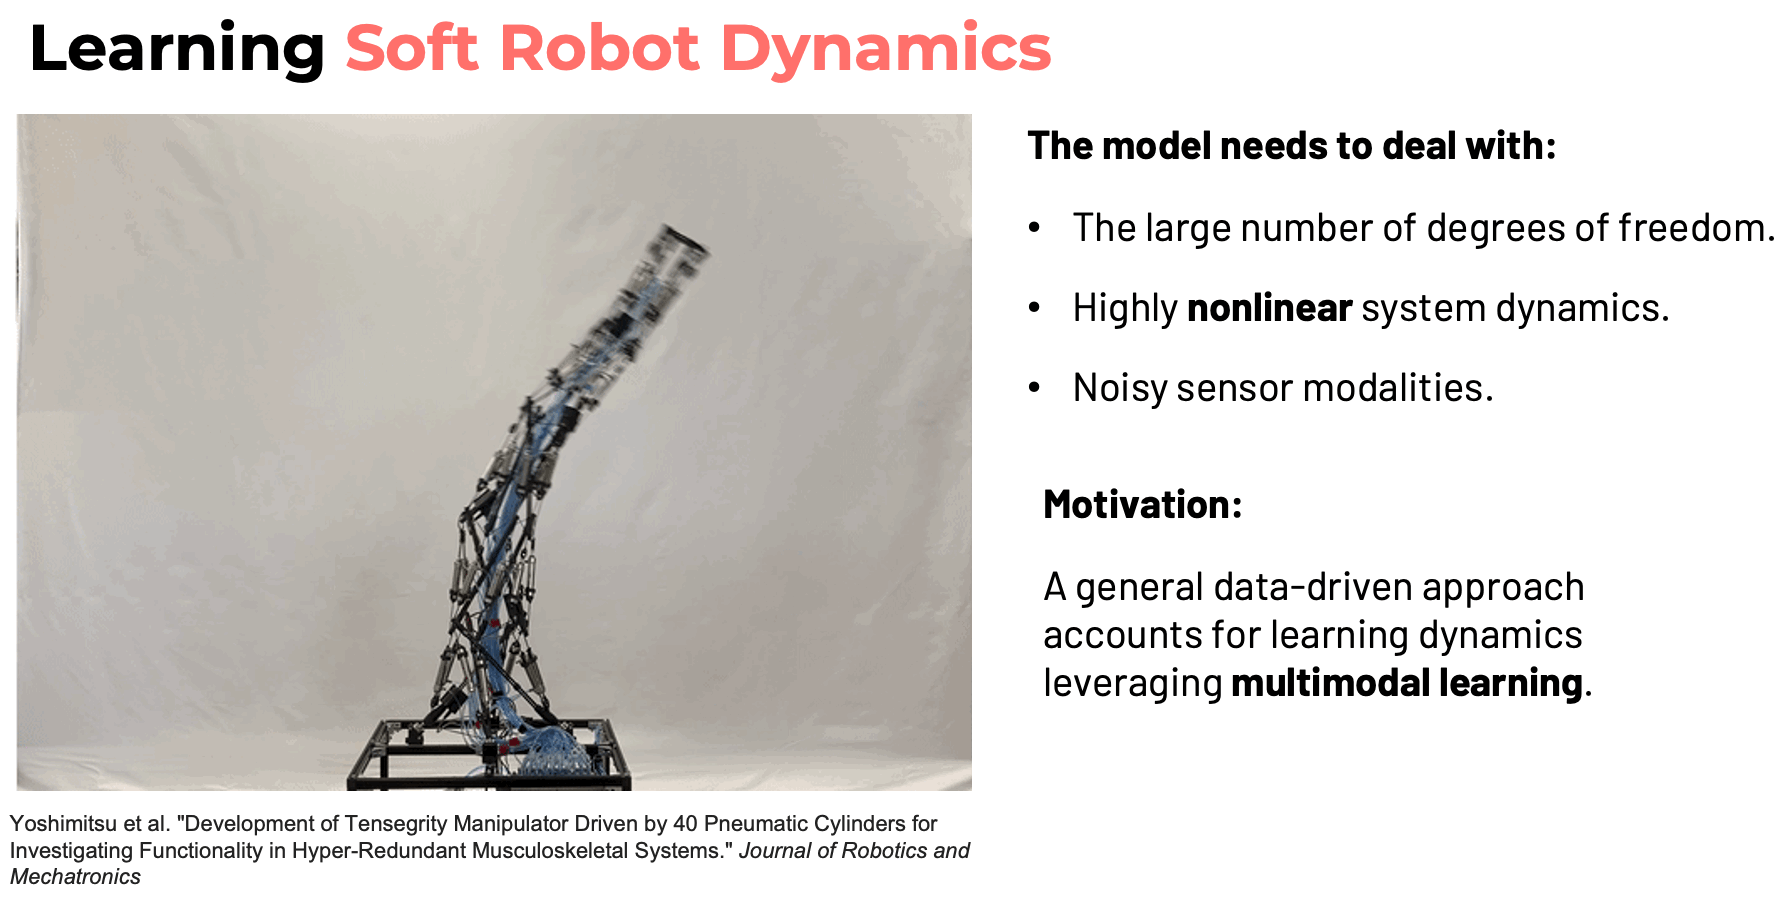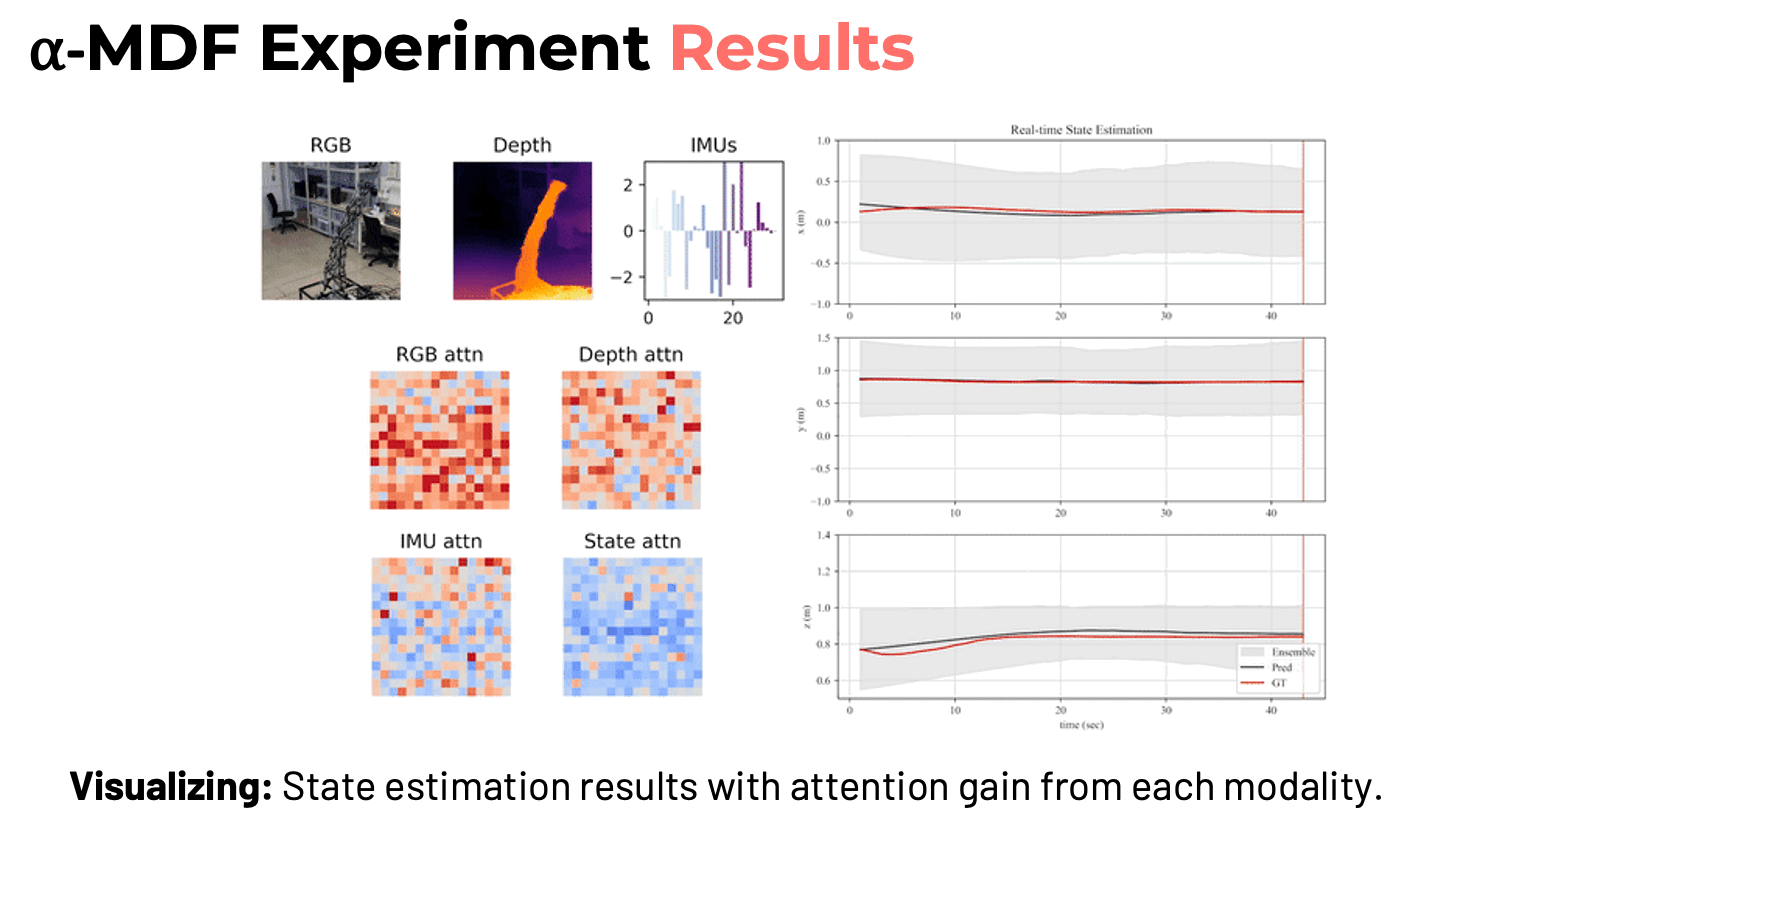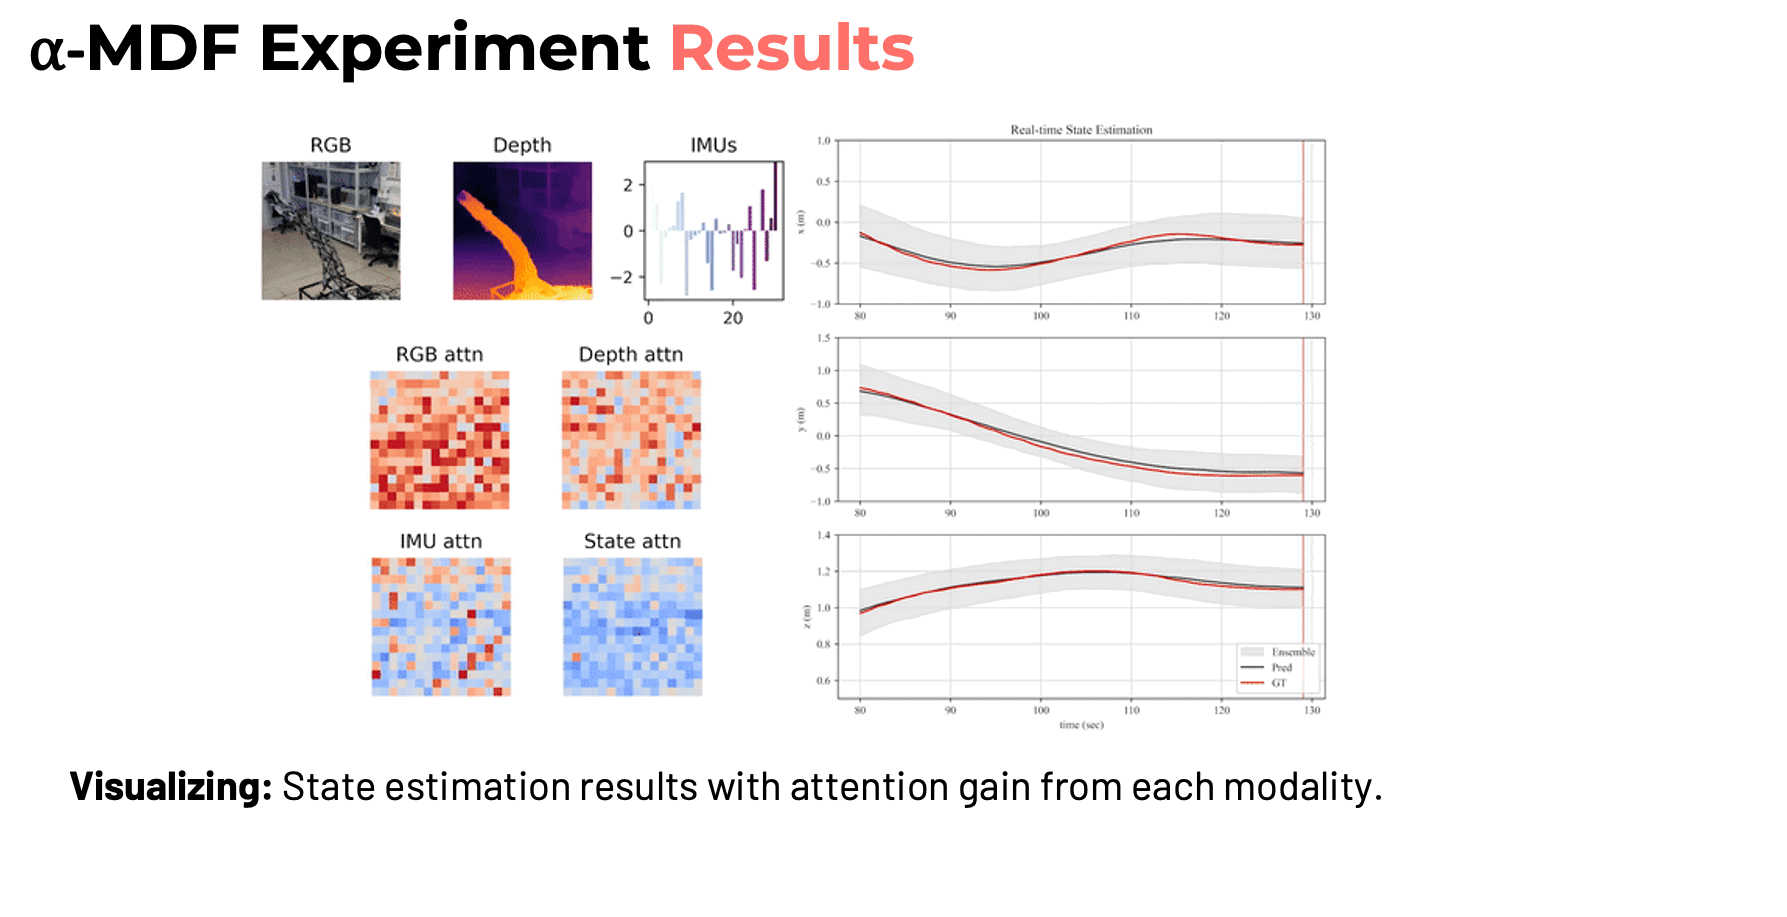
Multimodal Learning of Soft Robot Dynamics using Differentiable Filters
Xiao Liu, Yifan Zhou, Shuhei Ikemoto, Heni Ben Amor
CoRL 2023 Workshop on Learning for Soft Robots, 2023 · Project Page · Paper
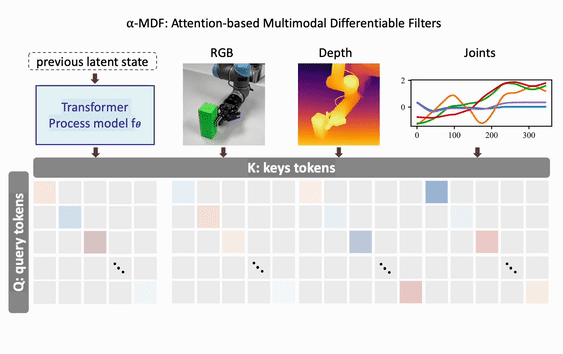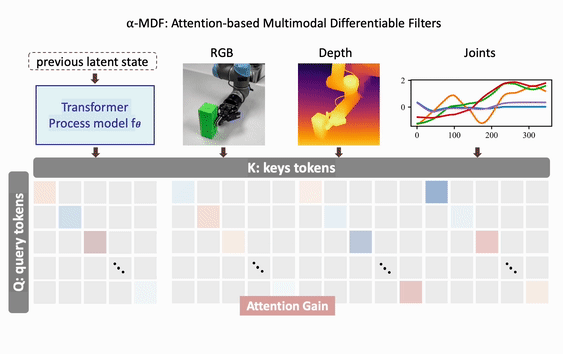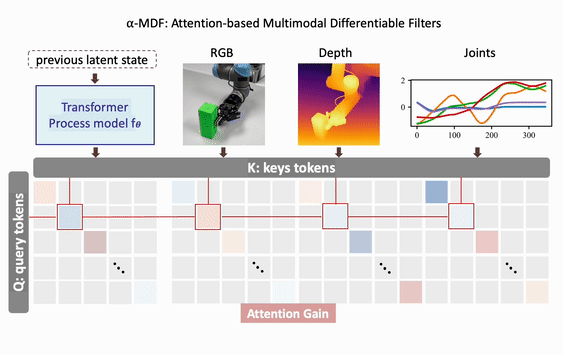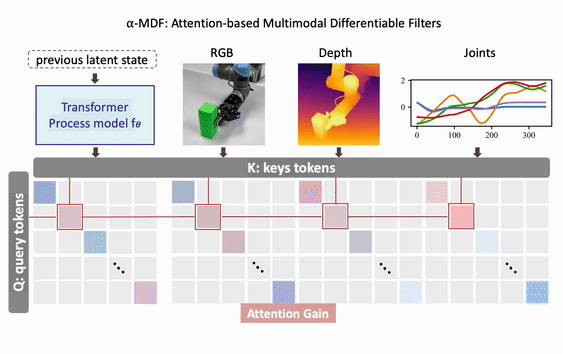
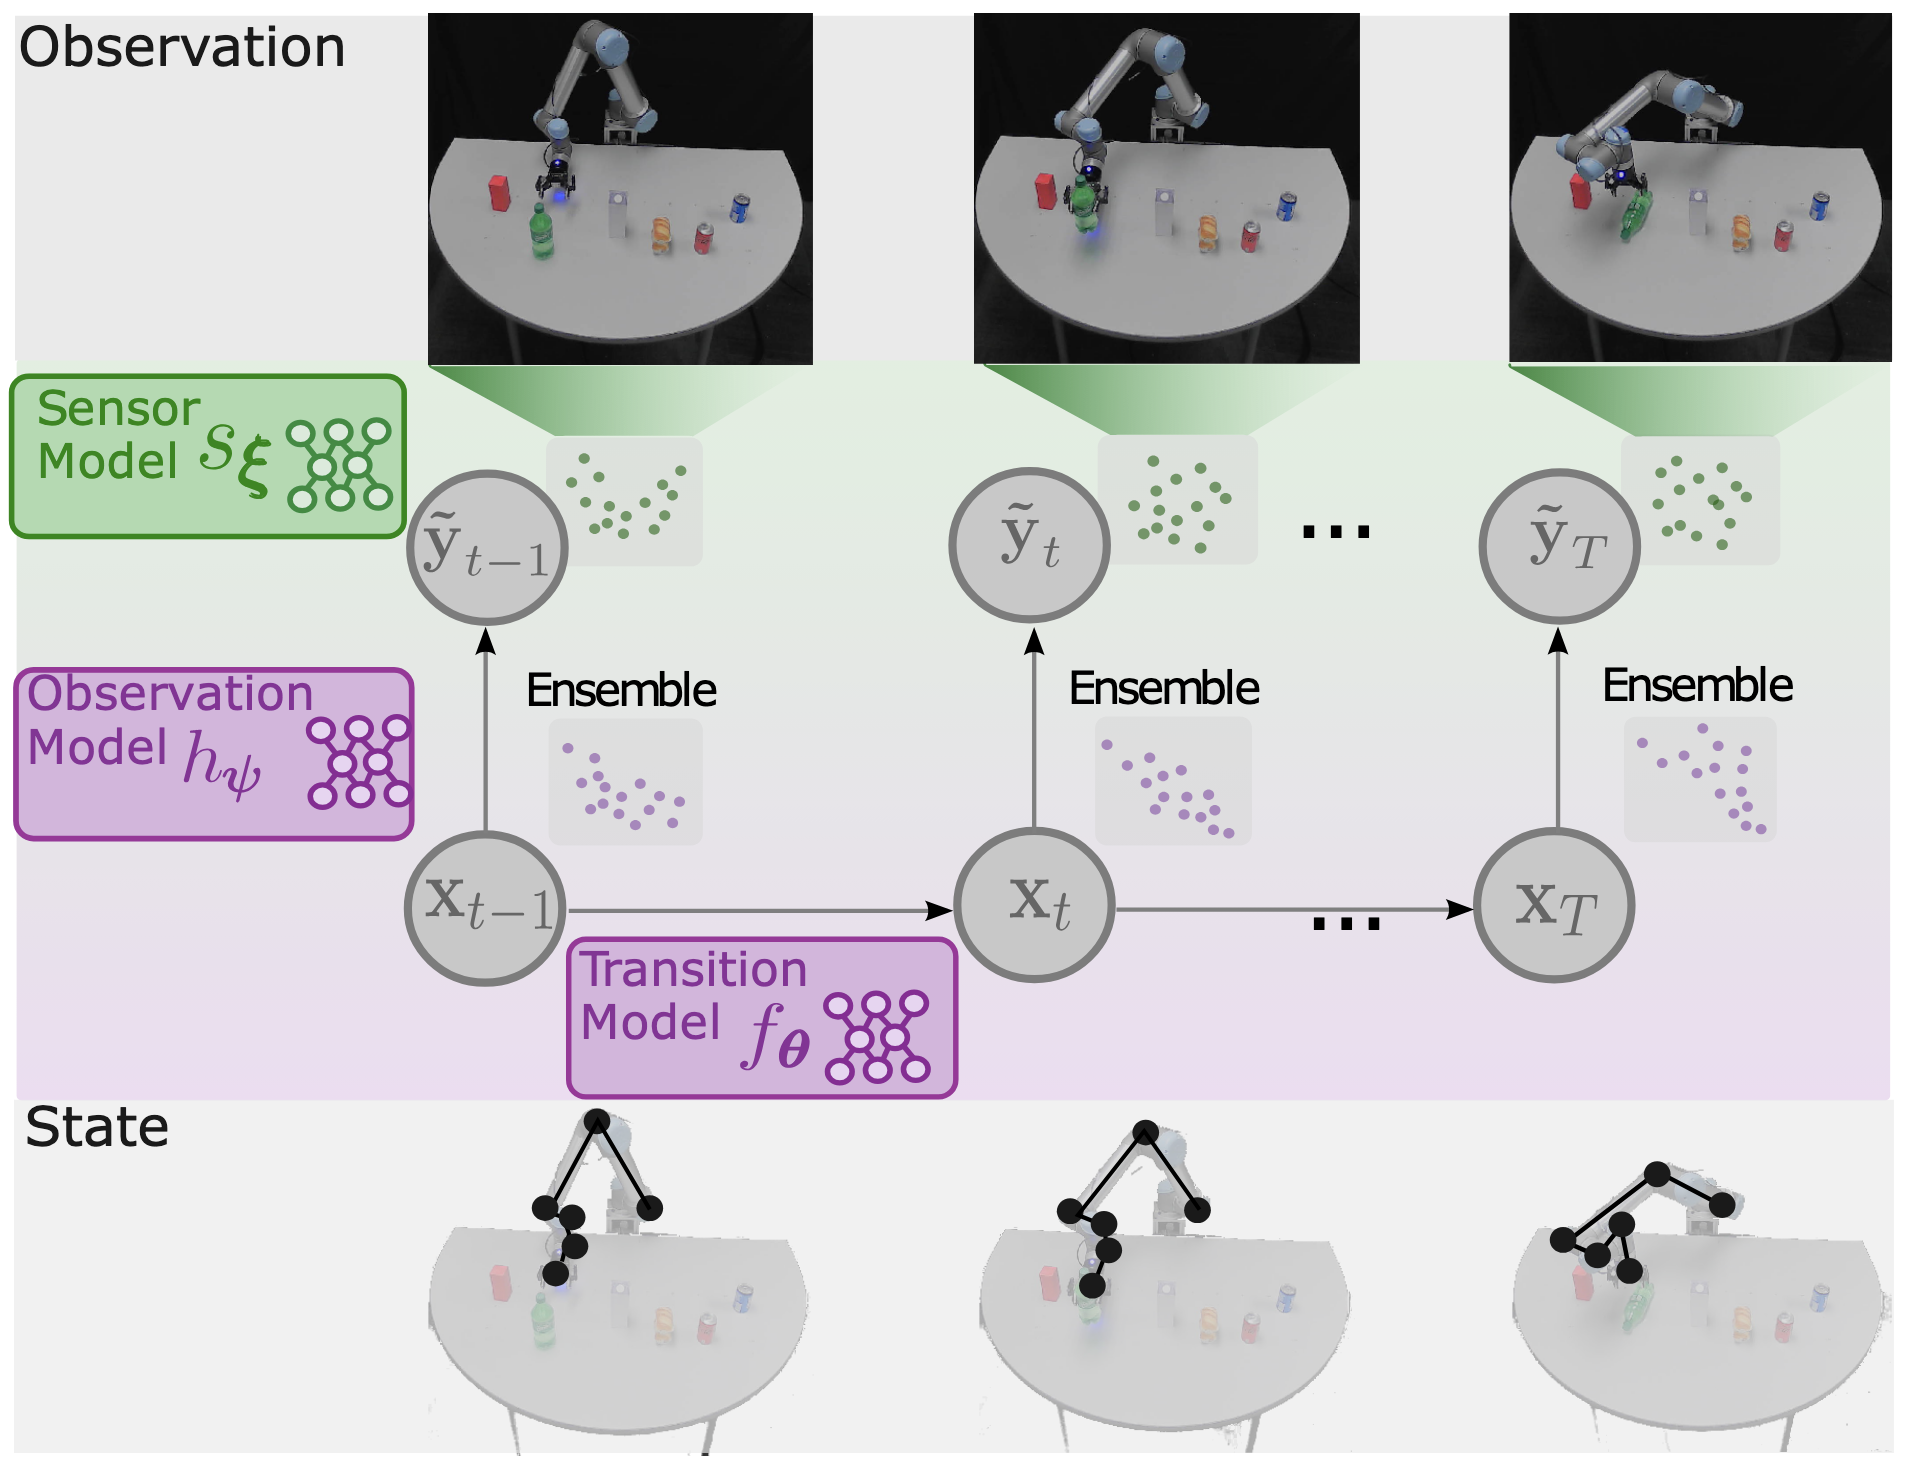
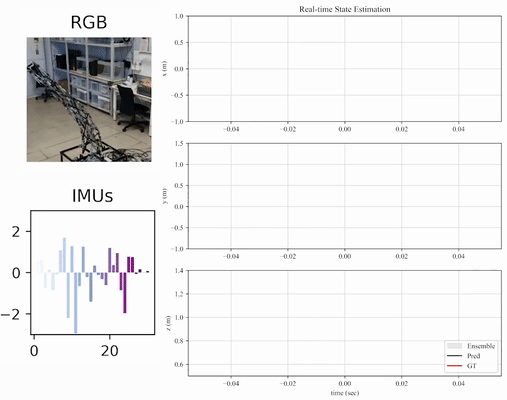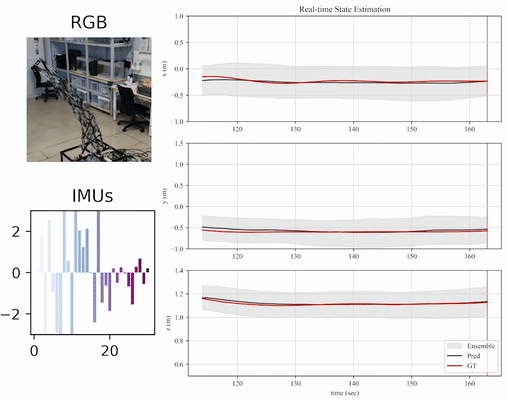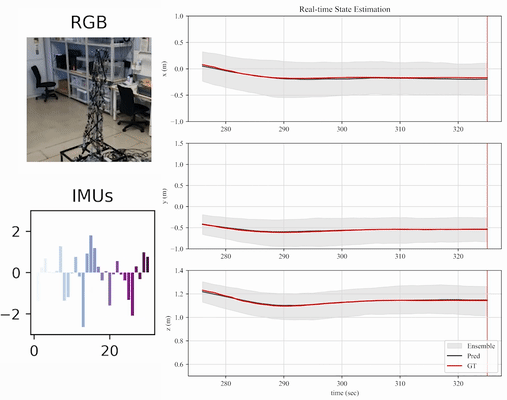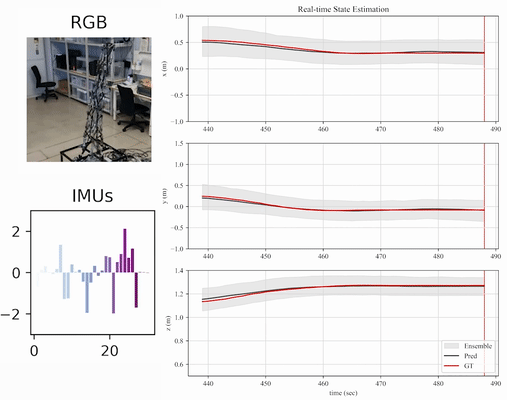
α-MDF: An Attention-based Multimodal Differentiable Filter for Robot State Estimation
Xiao Liu, Yifan Zhou, Shuhei Ikemoto, Heni Ben Amor
7th Conference on Robot Learning (CoRL), 2023 · Project Page · Paper · Video
Probabilistic Differentiable Filters Enable Ubiquitous Robot Control with Smartwatches
Fabian Weigend, Xiao Liu, Heni Ben Amor
IEEE IROS Workshop DiffPropRob, 2023 · Project Page · Paper
Enhancing State Estimation in Robots: A Data-Driven Approach with Differentiable Ensemble Kalman Filters
Xiao Liu, Geoffrey Clark, Joseph Campbell, Yifan Zhou, Heni Ben Amor
IEEE International Conference on Intelligent Robots and Systems (IROS), 2023 · Project Page · Paper
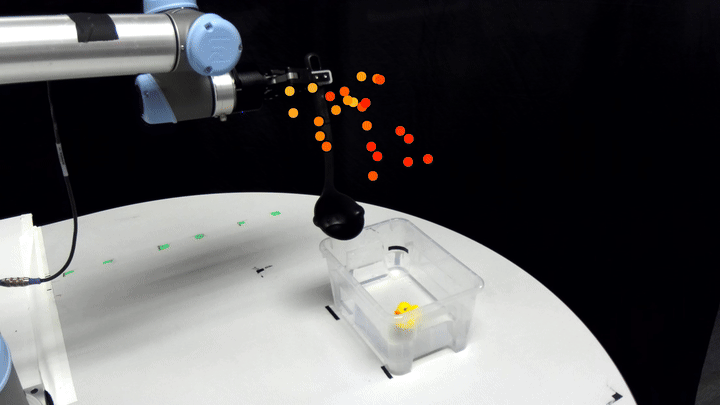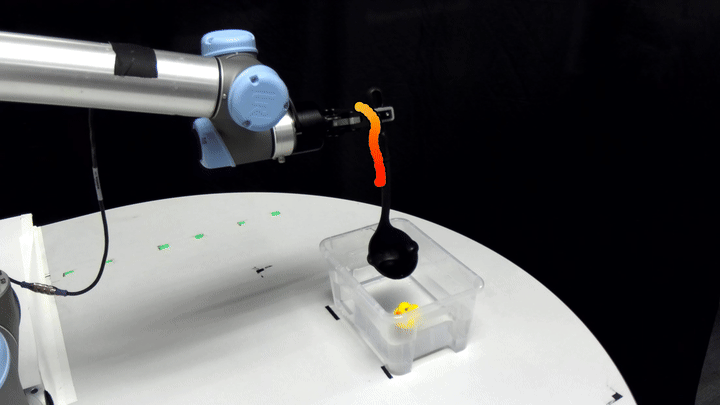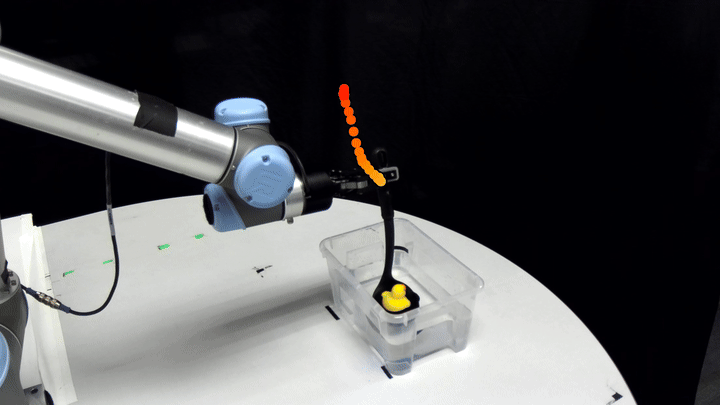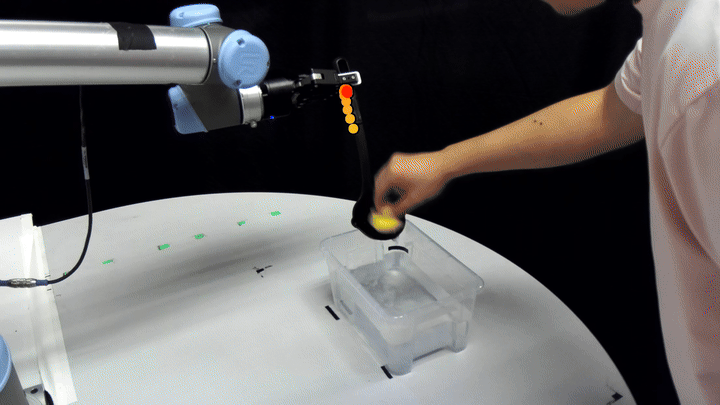
Learning Soft Robot Dynamics using Differentiable Kalman Filters and Spatio-Temporal Embeddings
Xiao Liu, Shuhei Ikemoto, Yuhei Yoshimitsu, Heni Ben Amor
IEEE International Conference on Intelligent Robots and Systems (IROS), 2023 · Project Page · Paper
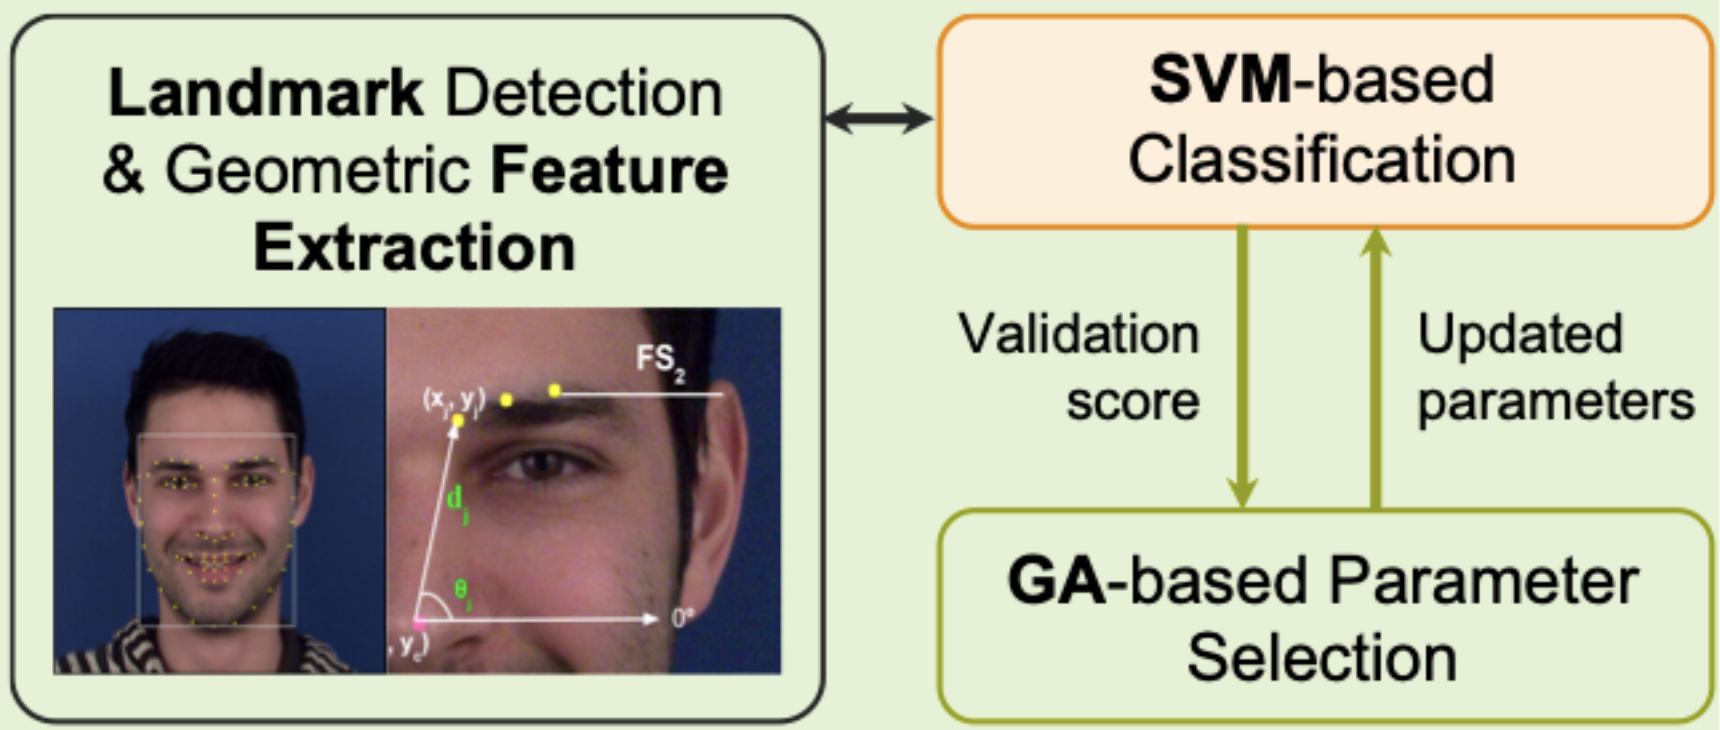
GA and SVM based Facial Emotion Recognition using Geometric Features
Xiao Liu, Xiangyi Cheng, Kiju Lee
IEEE Sensors Journal 21, no. 10: 11532-11542, 2021 · Code · Paper
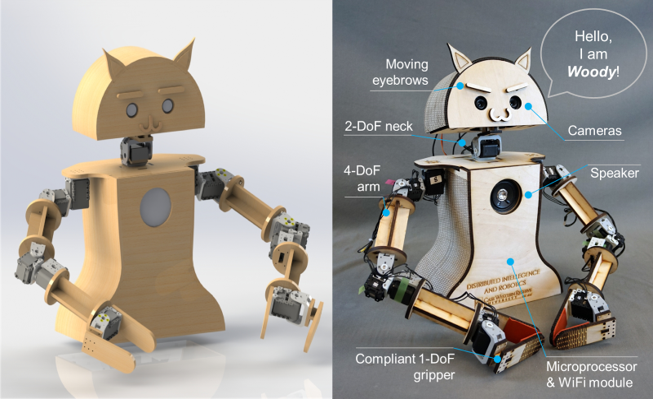
Woody: Low-Cost Open-source Humanoid Torso Robot
Daniel Hayosh, Xiao Liu, Kiju Lee
IEEE 17th International Conference on Ubiquitous Robots (UR), pp. 247-252, 2020 · Project Page · Paper
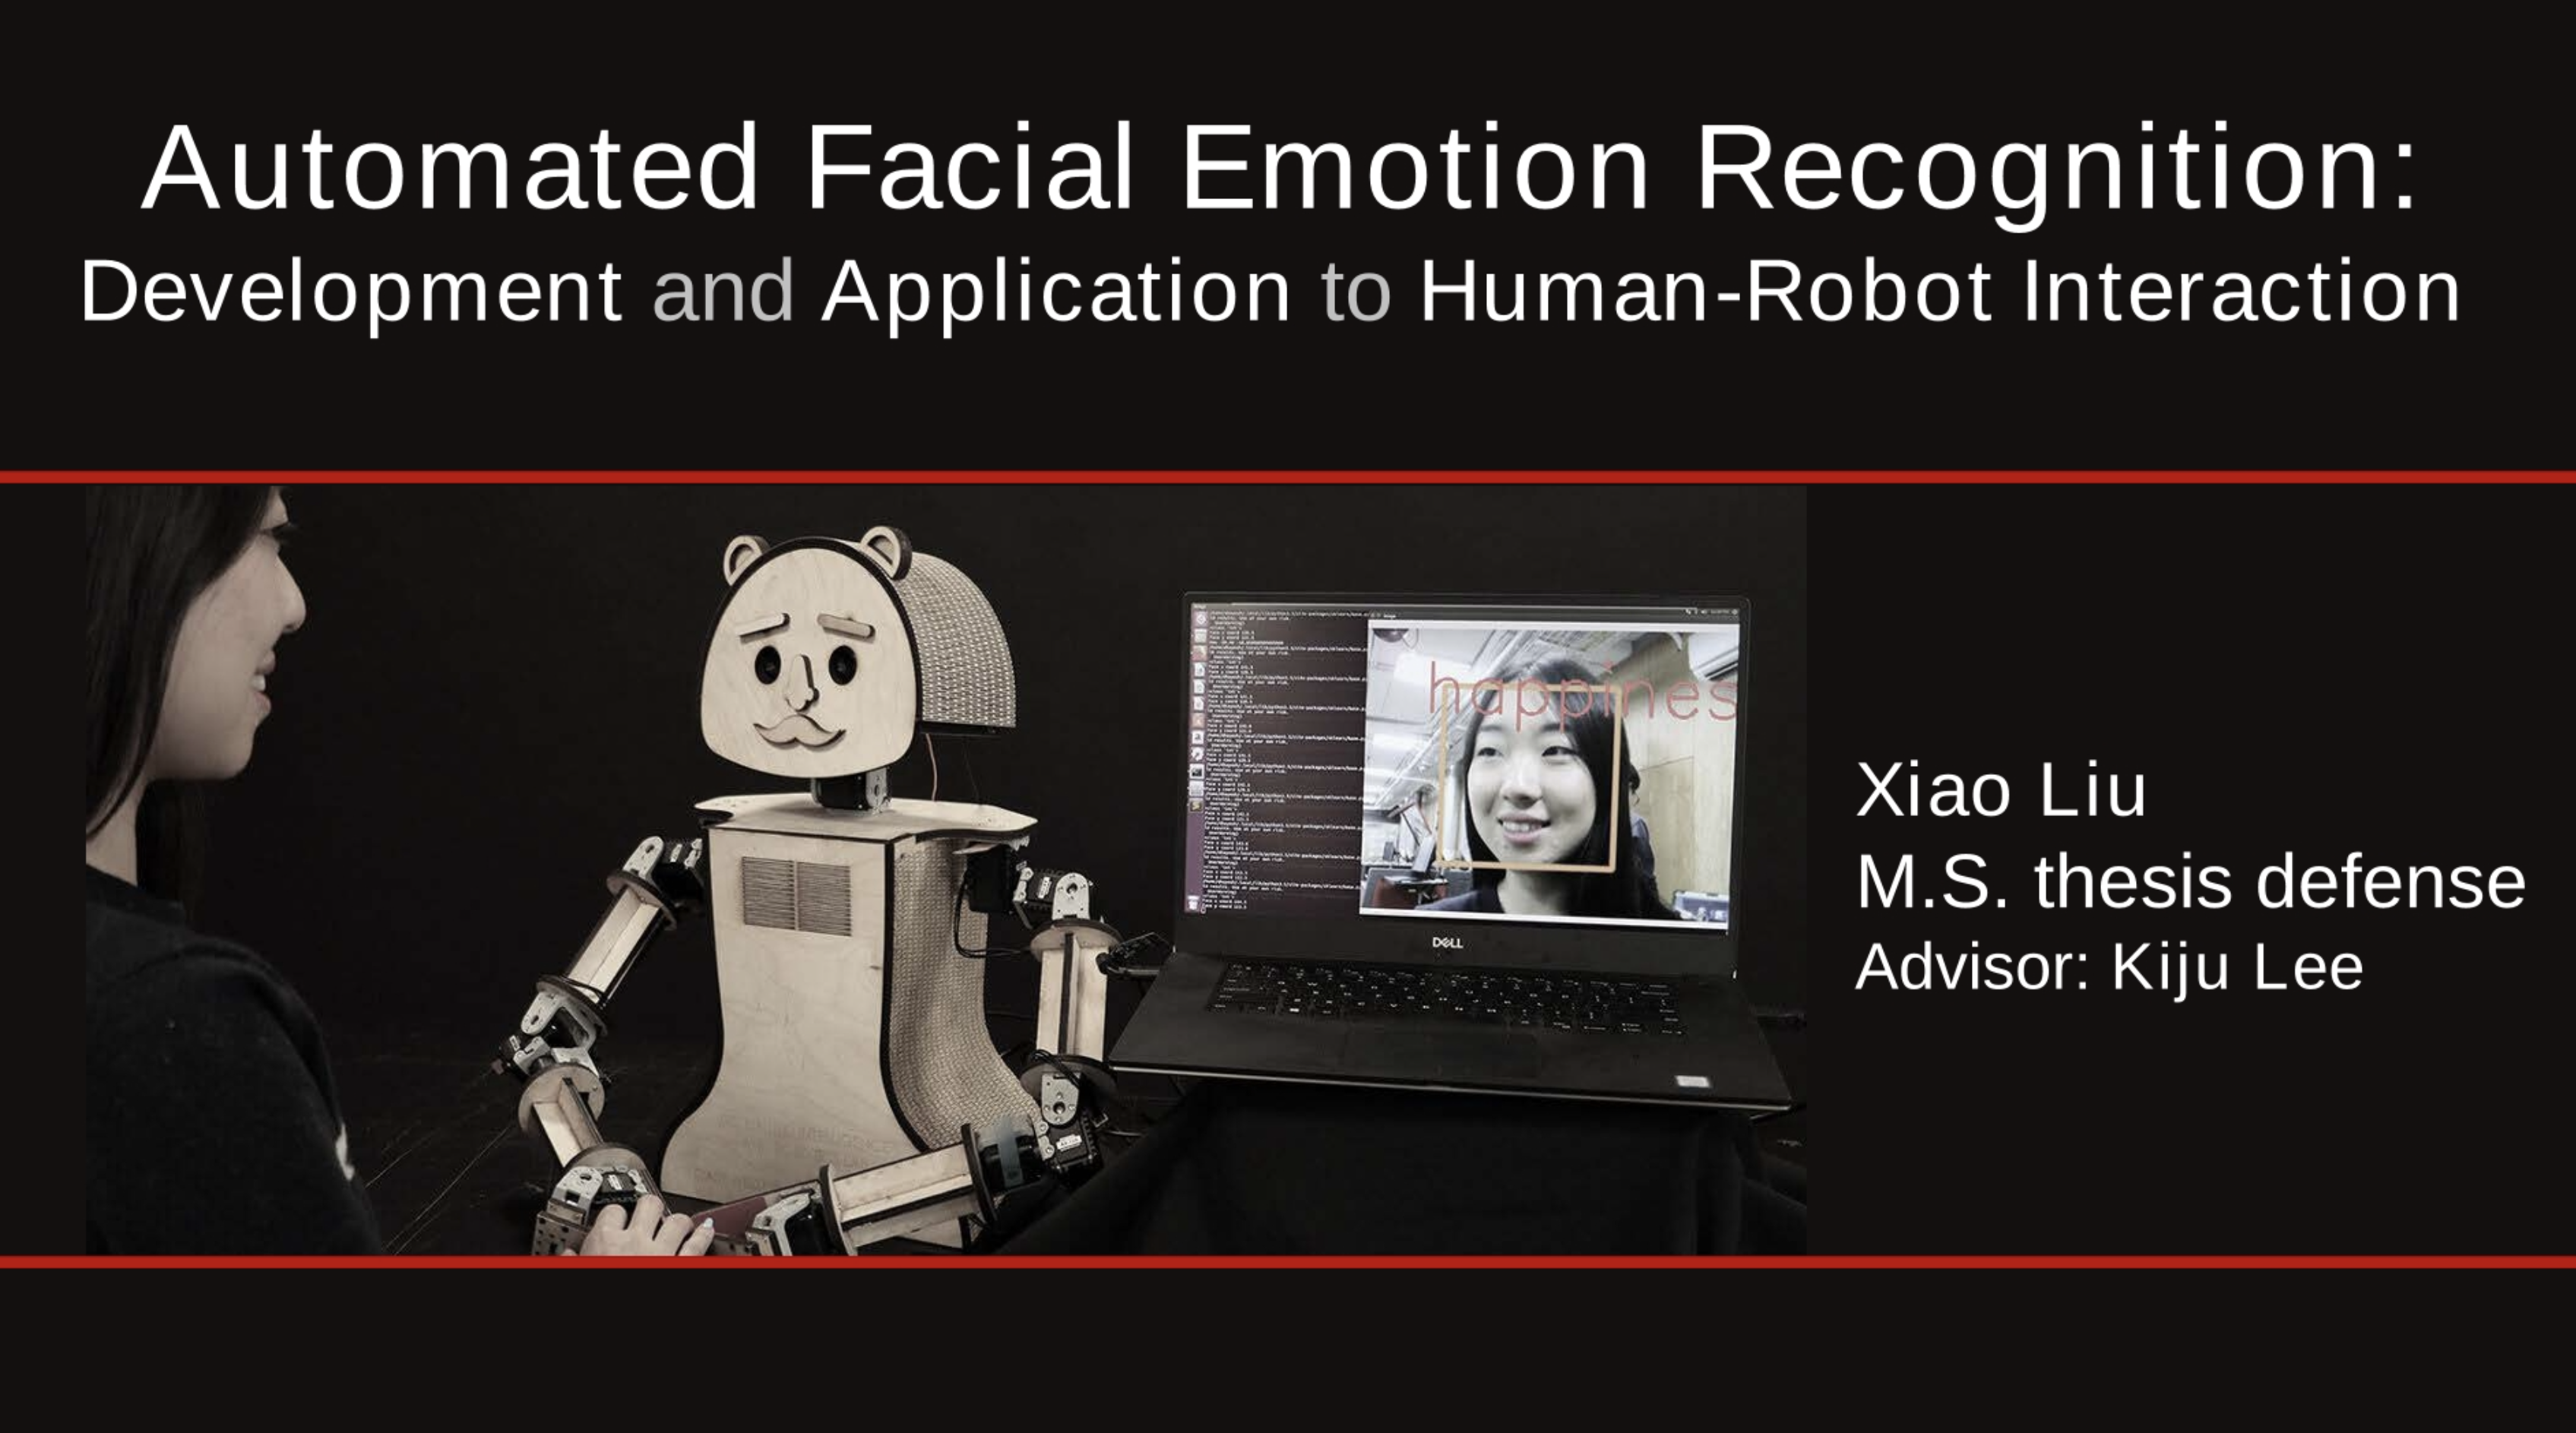
Optimized Facial Emotion Recognition Technique for Assessing User Experience
Xiao Liu, Kiju Lee
IEEE Games Entertainment and Medias Conference. pp. 1-9, 2018 · Paper

Education

  • Ph.D. in Computer Science, 2019 - 2024
    Arizona State University, Computer Science & Robotics
  • M.S. in Mechanical Engineering, 2016 - 2019
    Case Western Reserve University, Automation & Robotics

Awards

  • Graduate College Travel Award
    Recipient of 2023-24 Graduate College Travel Award Q2 $300 (2023)
  • Scholarships
    Recipient of Clapp Memorial Scholarship $1,882 (2018)
  • Fundings
    Recipient of think[Box] student project grant $2,500 (2018)

Skills

  • Robot State Estimation
  • Probabilistic Inference Modeling
  • Robot Perception
  • Proficient in
    • Linux/Docker/Kubernetes
    • Python/C/C++/Java/Matlab
    • TF/PyTorch/ROS/MuJoCo

Teaching

  • TA of EMAE250 (Computers in Mechanical Engineering)
    • Lecturer of the coding session (Matlab+Python)
  • TA of CSE205 (Object-Oriented Programming and Data Structures)
    • Lecturer of the coding session (Java)
  • TA of CSE548 (Advanced Computer Network Security)